
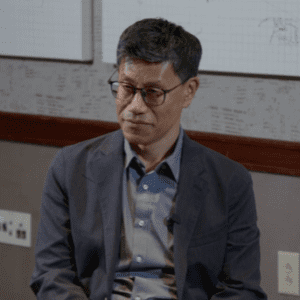
Jee-Hwan Ryu was born in Incheon, South Korea. He received a bachelor’s degree in Mechanical Engineering from Inha University in 1995, and his master’s and Ph.D. degrees in Mechanical Engineering from KAIST in 1997 and 2002, respectively. He is currently a Professor in the Department of Civil and Environmental Engineering at KAIST, where he also serves as Director of the KAIST Robotics Program. Prior to this, he was a Professor and Dean of the School of Mechanical Engineering at Koreatech. His previous academic appointments include Visiting Scholar at the German Aerospace Center (DLR) and Visiting Professor at Stanford University.
Ryu is currently the Editor-in-Chief of the IEEE Transactions on Haptics, Program Coordinator of the IEEE Robotics and Automation Society Distinguished Lecturer Program, and President of the Korea Haptics Society. He has served as a Senior Editor of IEEE Robotics and Automation Letters and as General Chair of several international conferences, including AsiaHaptics and Ubiquitous Robots.
Ryu’s research interests include haptics, teleoperation, human-robot physical interaction, and soft robotics. He is best known for developing the Time Domain Passivity Approach (TDPA), which has significantly advanced the stability and transparency of interactive robotic systems. In recognition of his contributions, he was named an IEEE Fellow and has received several honors, including the 2023 KAIST Technology Innovation Award, the 2019 Korea Robotics Society Robotics Innovation Award, and the 2015 IEEE Most Active Technical Committee Award.